Assembly sequence anomaly detection (SOP monitoring)
Contributed to a camera-based pipeline that detects departures from expected assembly sequences.
YOLO · ONNX · Edge inference
AI ARCHITECT / ALGORITHM ENGINEER
I build computer vision, edge AI, and LLM systems for industrial inspection, robotics, and workflow automation.
The AI platform lifecycle, from camera datasets to edge devices.
Organize camera data into datasets and prepare labels for training and evaluation.
Train vision models, review metrics, and test predictions with held-out images or independent video.
Compose workflows, simulate models, and package compatible models for cloud or edge inference.
Connect device tasks and review detections, events, and operational reports.
Projects and application areas I contributed to as an AI Architect Engineer.
Factory cameras for process monitoring, visual inspection, and safety.
Contributed to a camera-based pipeline that detects departures from expected assembly sequences.
YOLO · ONNX · Edge inference
Built scheduled summaries of abnormal assembly sequences, with total counts and per-device breakdowns from algorithm results.
REST APIs · WeCom · Reporting
Contributed to real-time camera detection workflows for smoke and fire events.
YOLO · Video analytics
Worked on pose-analysis and zone-exit workflows that turn camera events into alerts.
Pose estimation · Workflow orchestration
Contributed to the team’s computer vision work for capturing readings, recording data, and surfacing abnormal values.
Contributed to industrial visual inspection work for identifying quality issues in critical components.
On-device perception and event-driven alerts for assistive scenarios.
Tested on-device video analysis for scenarios such as a covered face or movement toward stairs.
Horizon X5 · ROS2 · SmolVLM2
Contributed to care and wellness projects, which includes obstacle awareness and reminders for health and exercise.
Assistive vision · Edge AI
Contributed to the team’s elder-care work for helping people track and manage everyday tasks at home.
Contributed to computer vision scenarios for recognizing hazards in walking areas and generating alerts.
Participated in the elder-care application area for supporting assessment of instrumental activities of daily living (IADL).
Dataset, training, and evaluation workflows that support experimentation.
Integrated dataset and model operations into the AI workflow platform, including catalog views and model metrics.
Datasets · Model metrics · REST APIs
Integrated file-based model simulation, asynchronous result retrieval, and deployment plan operations.
Model evaluation · API orchestration
Tailored cloud-to-edge deployments, robot perception, and event automations.
Led work on a perception and control pipeline that combines gesture recognition, detection, and tracking for autonomous following.
ROS2 · Robot perception · Tracking
Worked on camera-based perception and ROS2 integration for robotic applications.
ROS2 · Camera perception · Robotics
Contributed to a workflow that maps recognized gestures to distinct actions.
Computer vision · Gesture recognition
Developed reusable workflow configurations for printer completion, doorway loitering, and courier delivery.
Event detection · Workflow templates
Worked on a 16-species detector, preparing YOLO datasets and evaluating recognition on separate wildlife videos.
YOLO · Dataset validation · Video evaluation
Optimized and packaged lightweight computer vision pipelines for GPU and edge environments.
ONNX Runtime · TensorRT · Docker
From training and evaluation to integration and deployment.
LLMS & AGENTS
Built a platform that turns natural-language requests into executable workflows for factory camera analytics.
Designed semantic retrieval with FAISS to match requests to available actions. The platform then uses tool calling and rule-based validation to build a workflow graph. Use cases included camera analytics, model simulations, and reporting.
INDUSTRIAL COMPUTER VISION
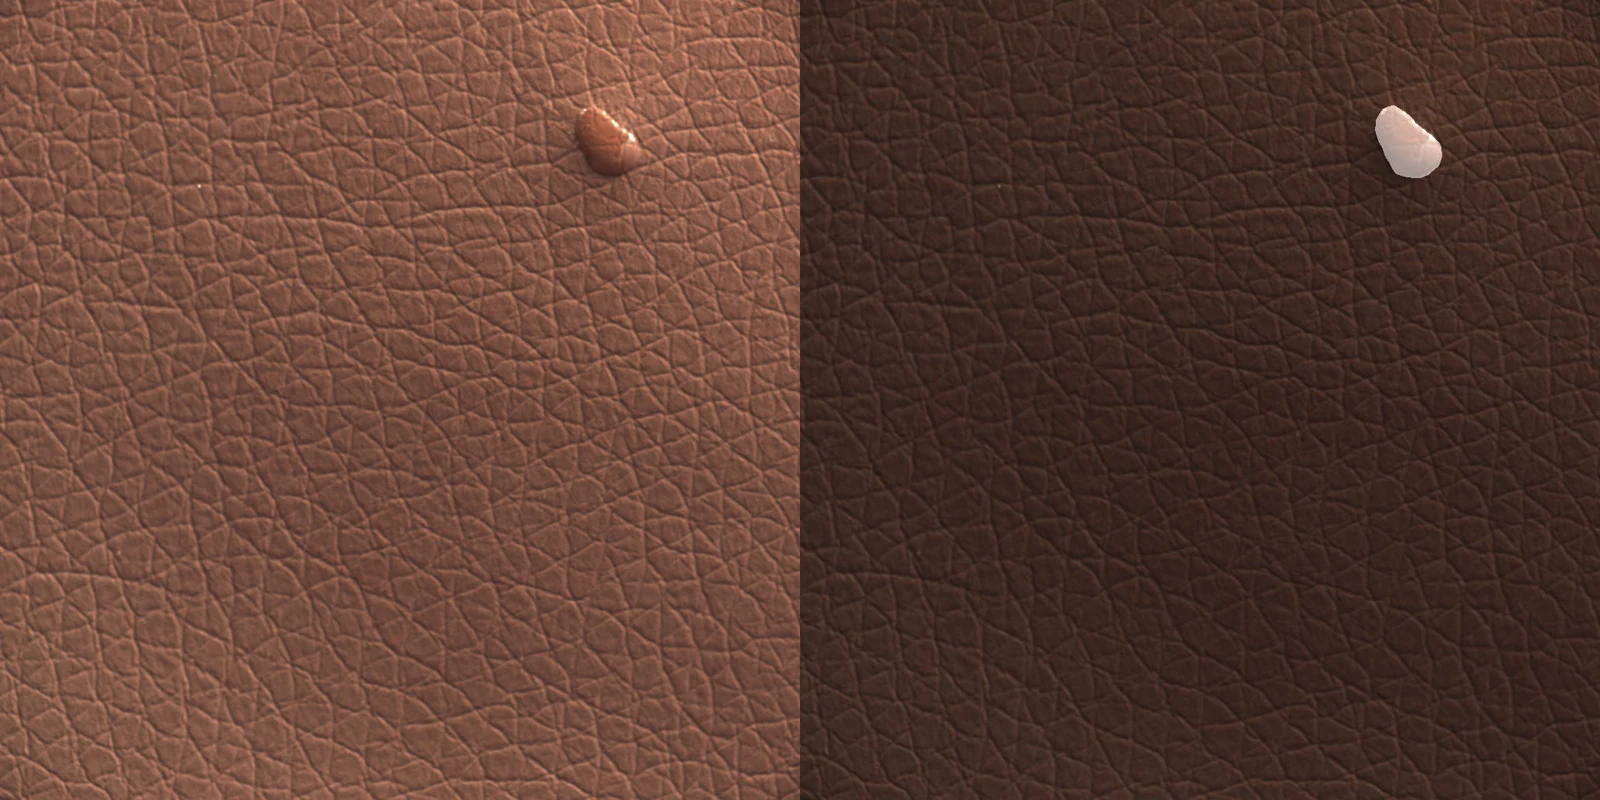
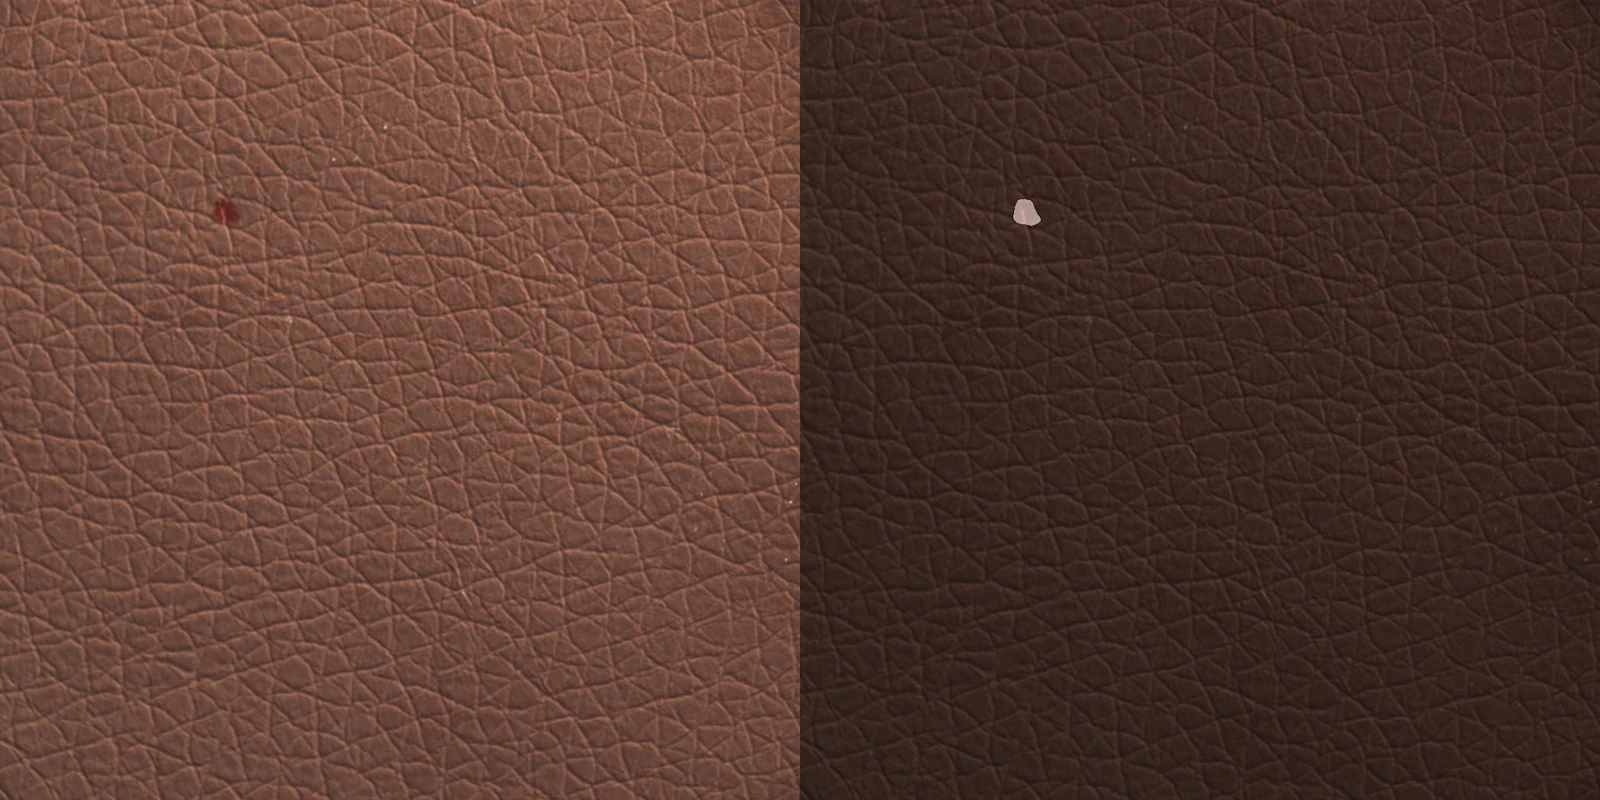
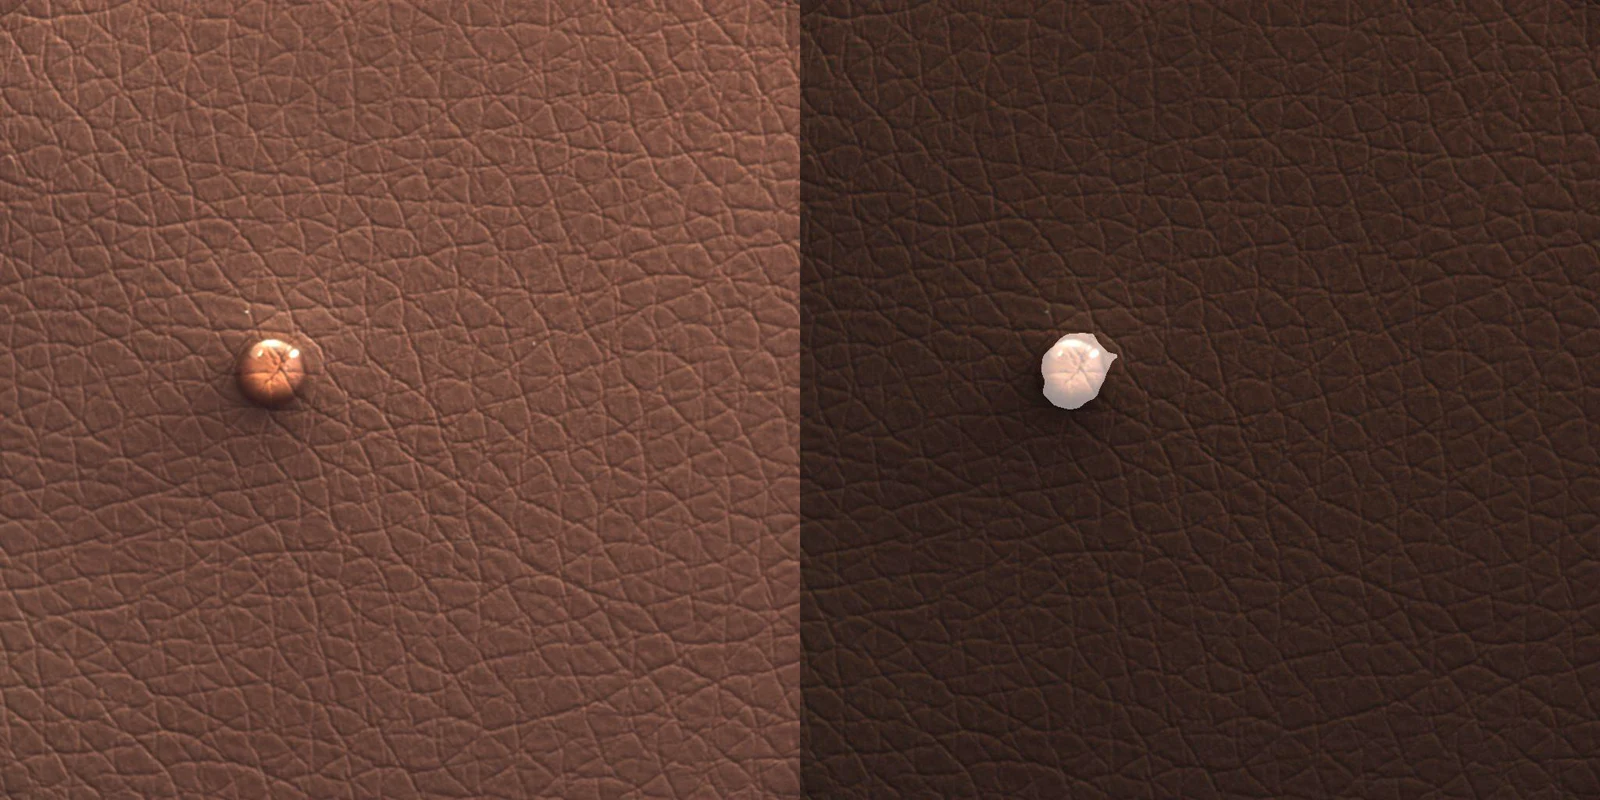
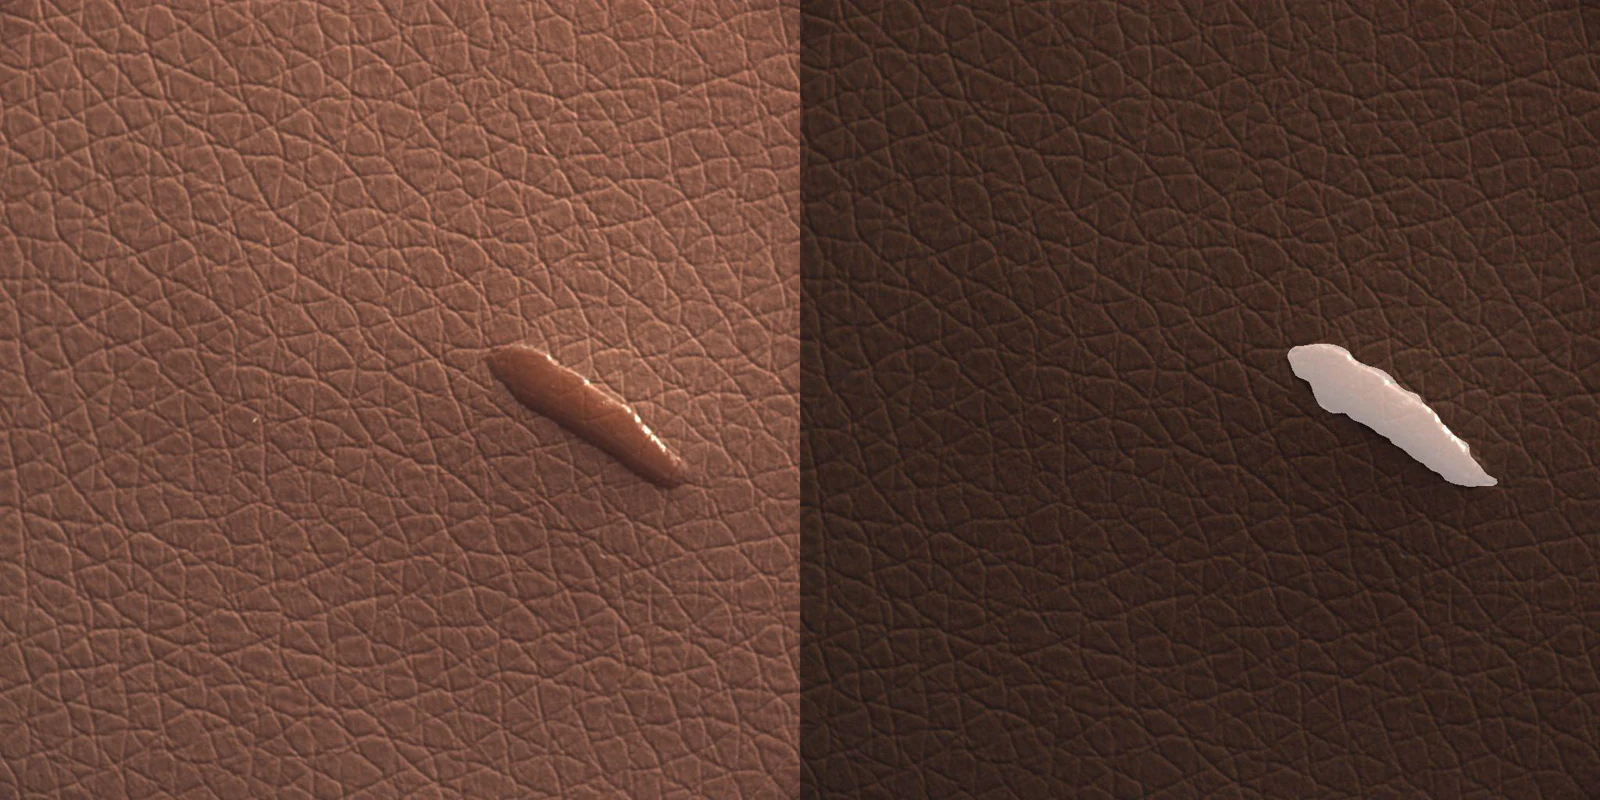
Developed detection and segmentation pipelines for visual inspection of leather surfaces.
Converted polygon annotations into masks, expanded and balanced the dataset, and compared YOLO and SAM-based approaches. Exported models to ONNX for the industrial inference pipeline.
ROBOTICS & EDGE AI
Led development of a visual perception and control pipeline for autonomous human following.
Combined gesture recognition, person detection, and visual tracking with robot control. The pipeline manages target selection and tracking as part of the following behavior.
MEDICAL IMAGING
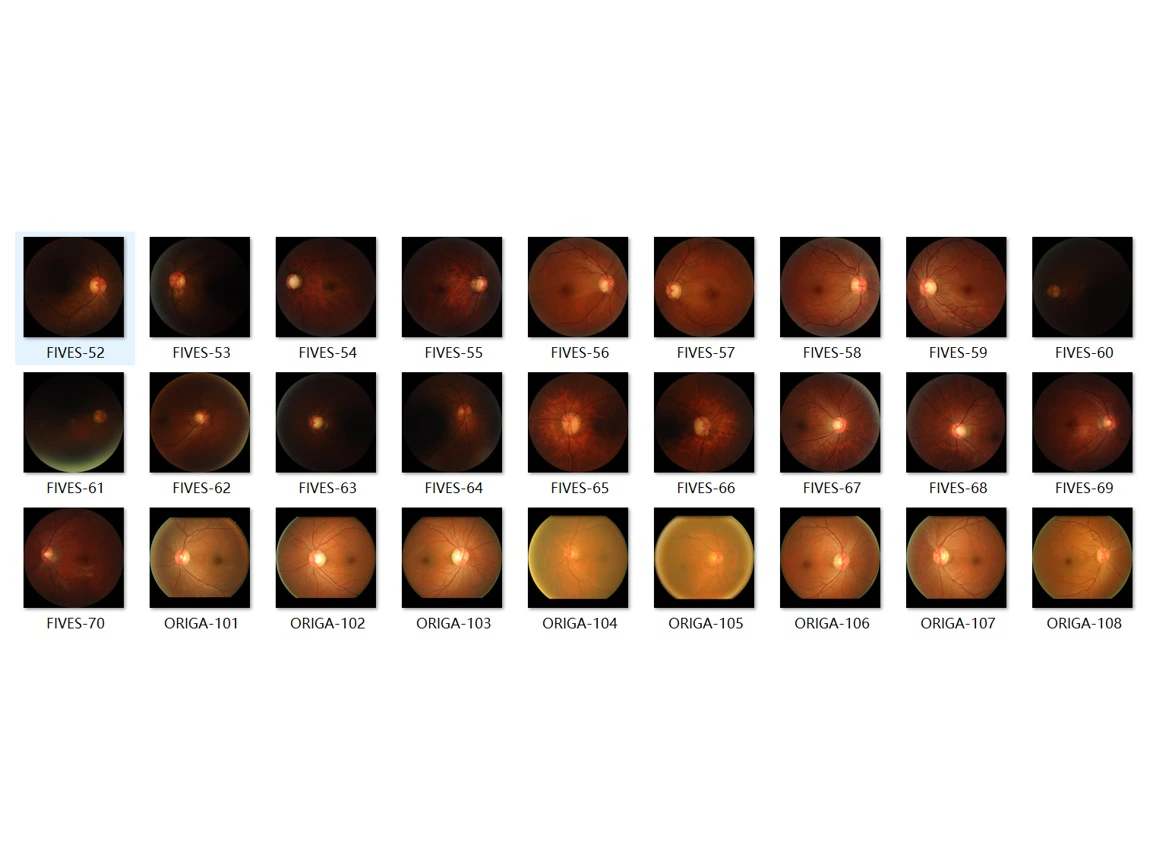
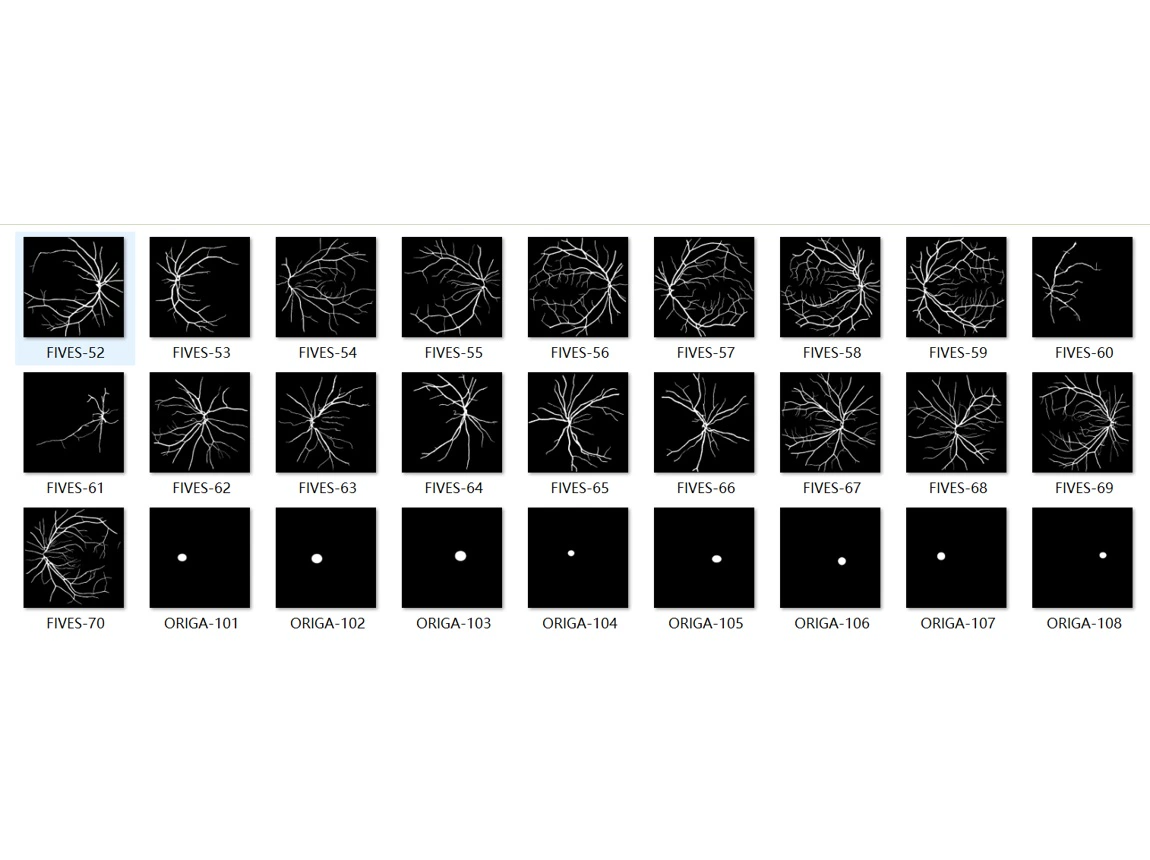
Evaluated detection and segmentation approaches for retinal imaging research.
Converted ophthalmic annotations to VOC-XML, trained models, and inspected predictions through visualizations. Compared SAM-based methods, MMSegmentation, and YOLO across imaging tasks.
ON-DEVICE AI PROOF OF CONCEPT
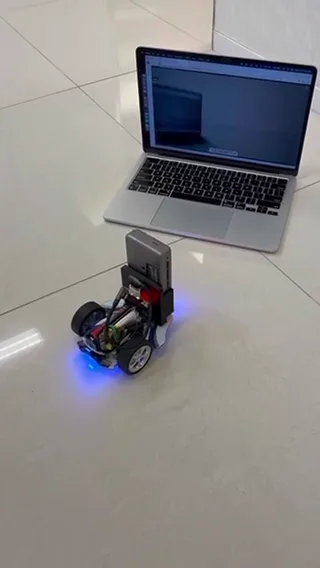
I built an on-device video monitoring prototype using ROS2 and SmolVLM2. It classifies sampled frames as SAFE or UNSAFE and records each decision with its frame ID and timestamp for review. Inference runs on the Horizon X5 board.
The prototype was tested on footage of a face covered by bedding and movement toward stairs, a kitchen, or an open door.
The report records an end-to-end test in which the model flagged a face fully covered by a blanket and the decision could be traced back to the source frame.
Memory constraints limited model size and required throttling the frame rate. In the slowest trials, a single decision took tens of seconds.
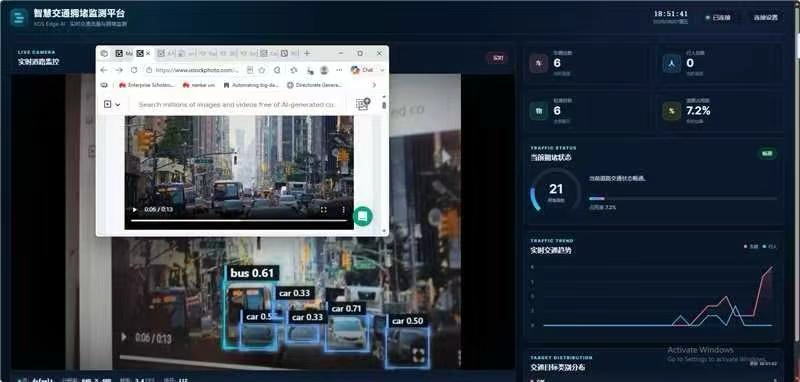
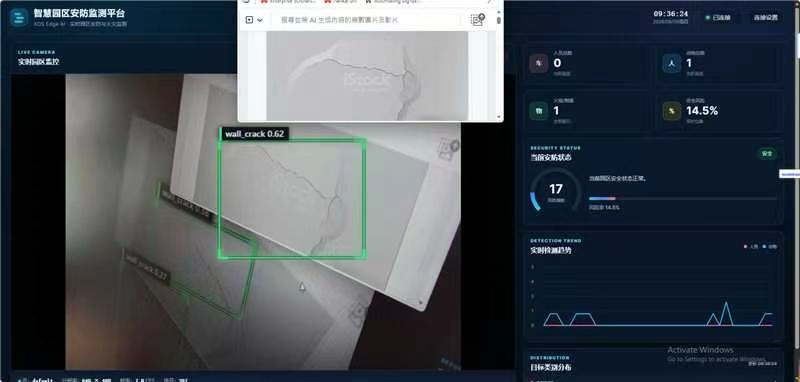
Retinal imaging, camera dashboards, RoboCar footage, and Leather-SAM results.
ESSEX BIOMEDICAL PHARMACEUTICAL
I built and evaluated fundus image workflows for diabetic retinopathy research. The work included converting annotations, training and comparing models, and visualizing regions of interest such as microaneurysms, hemorrhages, exudates, and cotton wool spots.
PUBLISHED MEDICAL IMAGING RESEARCH
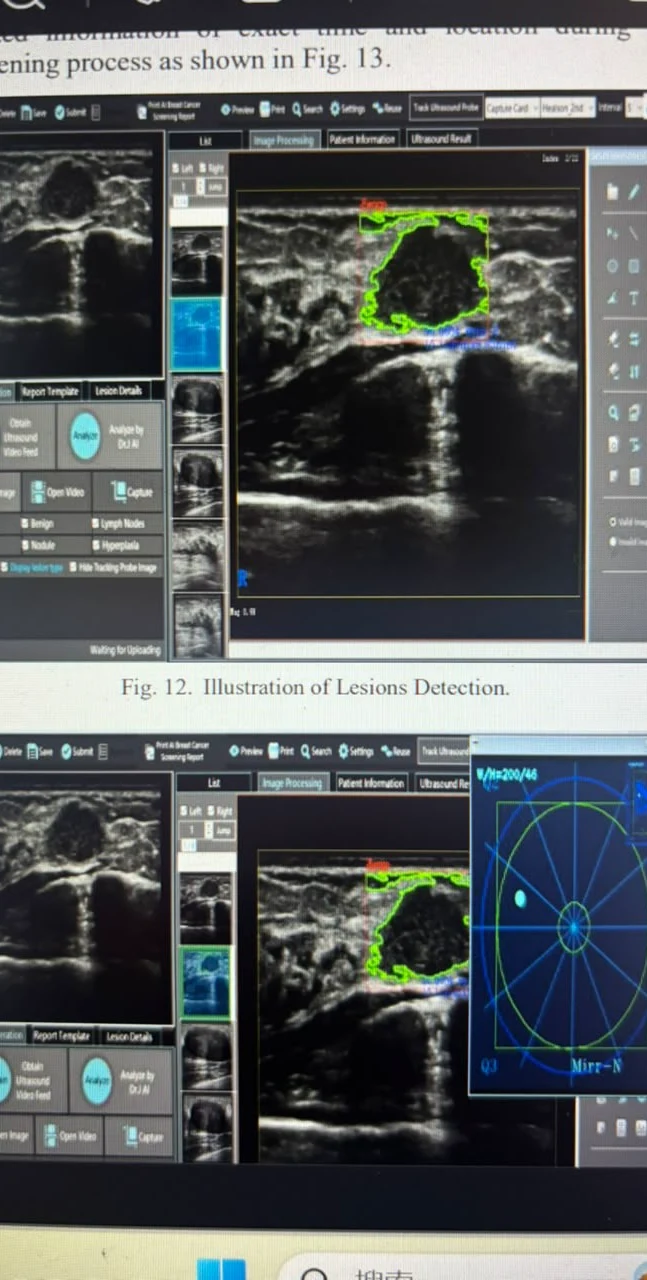
I co-authored the 2020 Dr.J paper on an AI-assisted preliminary screening system. The example shows how the research system outlined a finding in an ultrasound frame.
INDUSTRIAL VISUAL INSPECTION
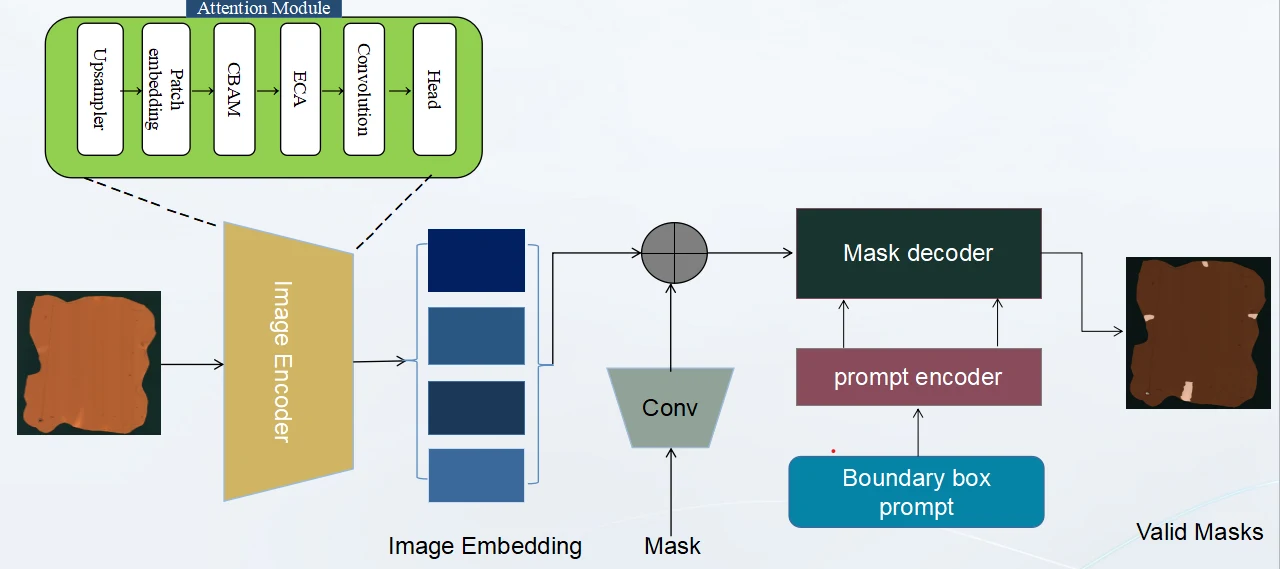
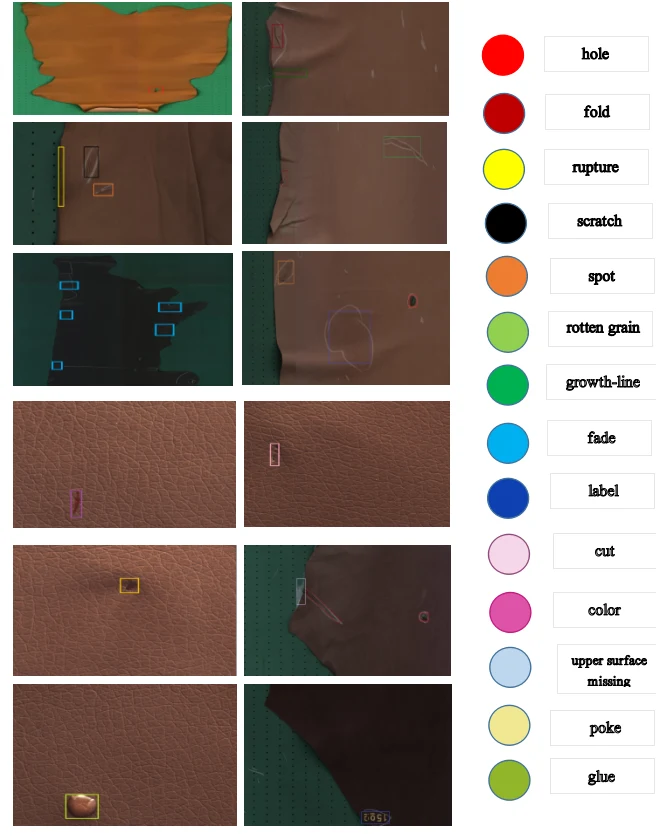
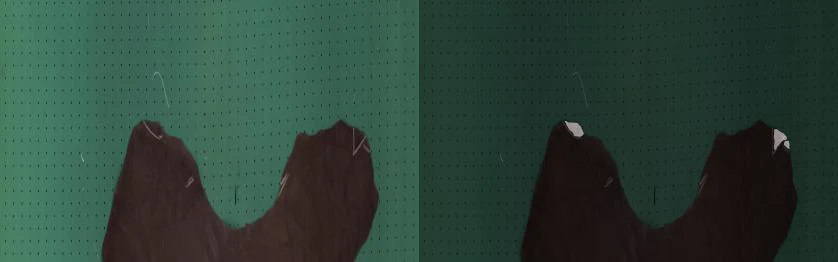
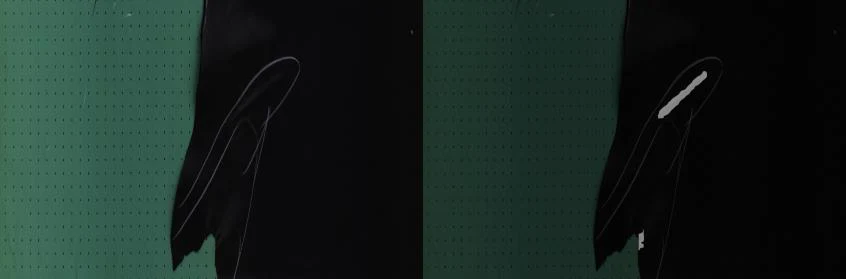
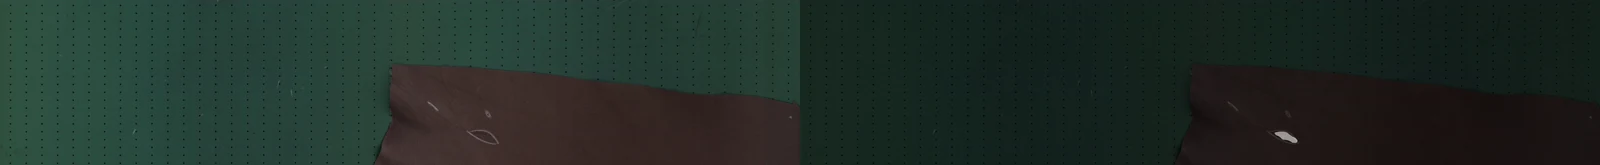
I adapted the Segment Anything Model for leather surface inspection by adding an attention mechanism to the encoder. I prepared LabelMe annotations, generated defect masks, compared predictions on leather samples, and exported the model to ONNX for future production use.
The project evaluation covered defects such as holes, cuts, scratches, folds, glue marks, and discoloration. Next steps documented in the project included expanding the labeled dataset and evaluating additional defect types.
BACKGROUND
I’m an AI architect and algorithm engineer with over six years of experience across Pakistan and China. I build computer vision, edge AI, and LLM systems, from training and evaluation through deployment.
MASTER’S THESIS · 2019
I developed Cas-GAN to help task-oriented dialogue systems choose actions that complete user requests in fewer turns. The model combines graph convolution for dialogue representations, adversarial learning, and reward-based policy optimization.
South China University of Technology · Supervisor Prof. Wang Zhenyu
| Dialogue policy | Task success |
|---|---|
| Cas-GAN | 66.25% |
| Hierarchical reinforcement learning | 64.85% |
| Reinforcement learning | 44.40% |
| Rule-based agent | 32.20% |
CONTACT
I’m based in Pakistan and welcome inquiries about AI engineering roles, project collaborations, and applied AI research.

